Meal planning for iOS.
React Native application for meal planning, grocery lists, and food journaling, with persistent local state and optional AI meal generation.
 Kshitij PrasadROBOTICS & SOFTWARE
Résumé
Robotics & software engineer.
I develop vehicle-data pipelines and ADAS scenario retrieval at Audi. Previously at Akkodis, I worked on ROS 2 integration and reinforcement-learning simulation.
01 / SELECTED PROJECTS
Software, robotics, and automotive data.
React Native application for meal planning, grocery lists, and food journaling, with persistent local state and optional AI meal generation.
Questionnaire preparation with source references, revision history, and approval controls for commercial insurance renewals.
Benchmarked PPO, SAC and TD3 in Gazebo/PX4 SITL with trajectory logging and repeatable evaluation. PPO achieved 5.5 cm mean final horizontal error over 100 simulation episodes.
Vehicle telemetry pipelines, computer vision, and CLIP semantic search for retrieving and reconstructing real driving scenarios.
An interactive fleet-planning prototype with simulated demand and an optional PPO backend. First place at the PAVE Europe Next Gen Challenge in Brussels.
Real-time perception, motion planning, and sensor integration in C++ / ROS 2 on NVIDIA Jetson for an autonomous Formula Student racecar.
FURTHER PROJECTS
Connecting perception, object detection, and navigation for a physical service robot.
A decision-support prototype combining explainable AI, data pipelines, and dashboards for aviation.
A Pixhawk-based platform for hardware assembly, flight-controller integration and future policy testing.
Exploring accident scenarios through simulation, reconstruction, and immersive visualization.
A peer-tutoring platform connecting students at TH Ingolstadt.
THREE.JS / INTERACTIVE VISUALISATION
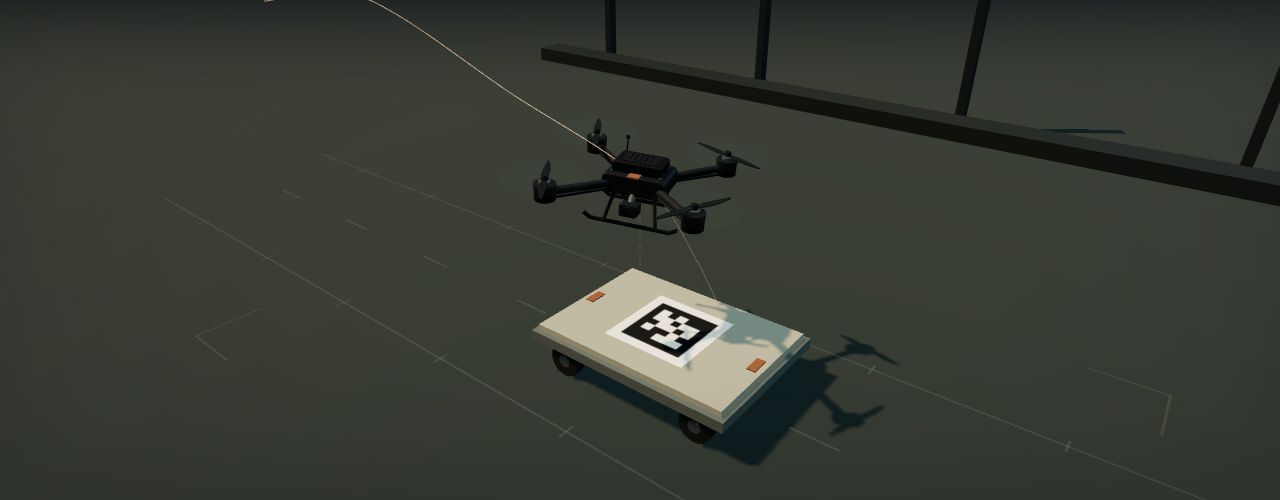
A Three.js illustration of a quadrotor approaching a moving platform. Pause the sequence, change the camera, or inspect a point on the timeline.
SCENARIO STATE
Illustrative trajectory. Recorded Gazebo runs and benchmark results are available in the research project.
Read the thesis ↗02 / EXPERIENCE
Vehicle-data processing and scenario retrieval for driver-assistance simulation.
Developed a Gazebo/PX4 SITL landing benchmark with ROS 2 integration, policy training, trajectory logging and standardized evaluation of PPO, SAC and TD3. Physical policy transfer remains future work.
ROS 2 service robot integration, C++ perception and sensor interfaces, Nav2 navigation, and CARLA simulation scenarios for automated driving evaluation.
Real-time motion planning, multi-sensor integration, and embedded C++ / ROS 2 software on NVIDIA Jetson for an autonomous racecar.
B.Eng. · Graduated 2026
UAV precision landing research
INGOLSTADT, DE
03 / BACKGROUND
I’m based in Ingolstadt, Germany, with a B.Eng. in Autonomous Vehicle Engineering from TH Ingolstadt. My experience includes automotive data processing at Audi, ROS 2 integration at Akkodis, and driverless software for Schanzer Racing.
I work primarily in C++, Python, and TypeScript. My independent projects include Nouri, a meal-planning app, and Scope, an insurance-renewal workflow.
TECHNOLOGIES
Software, simulation and hardware integration.
SQL · ROS 2 · Linux · Docker · Git
PPO · SAC · TD3 · CLIP · Computer vision
PX4 SITL · Digital twins
LiDAR · RealSense · GNSS · IMU
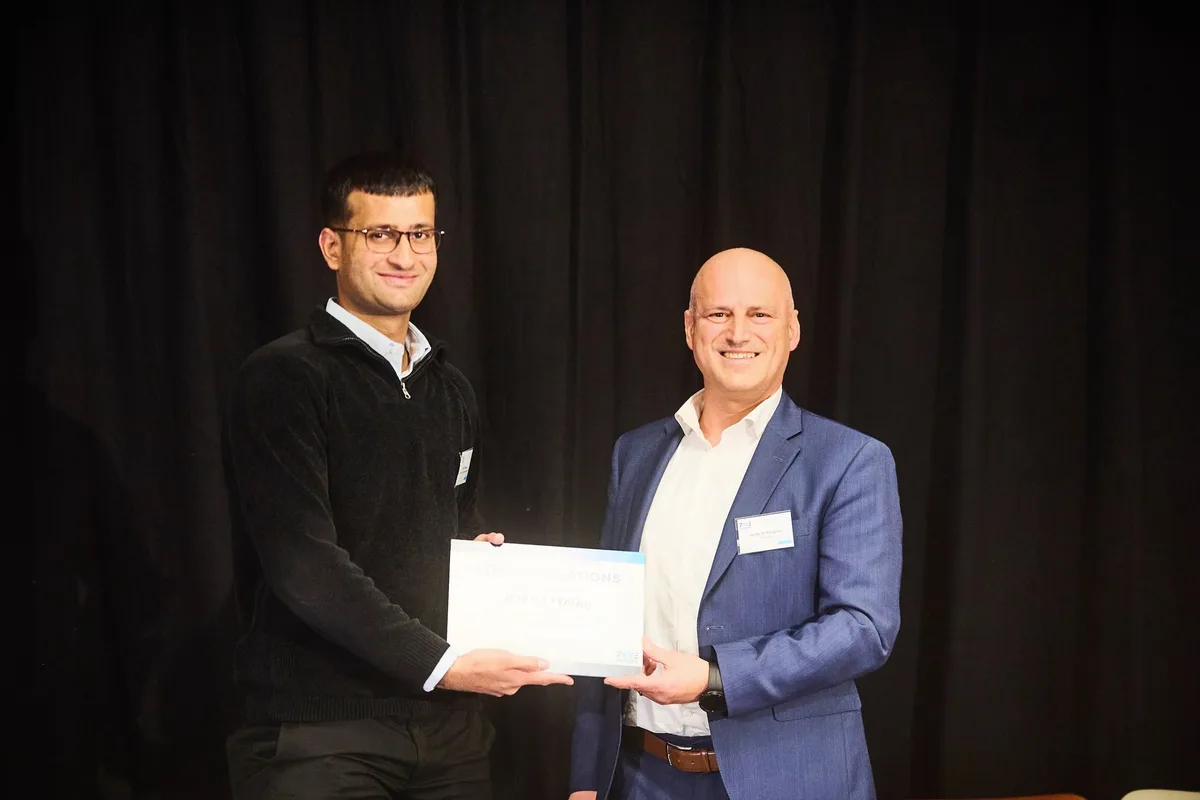
BRUSSELS / 2025
First place at the PAVE Europe Next Gen Challenge for work on autonomous mobility and public acceptance.
Recommendation from Prof. Dr.-Ing. Michael Mecking ↗Interactive fleet planning and traffic simulation prototype
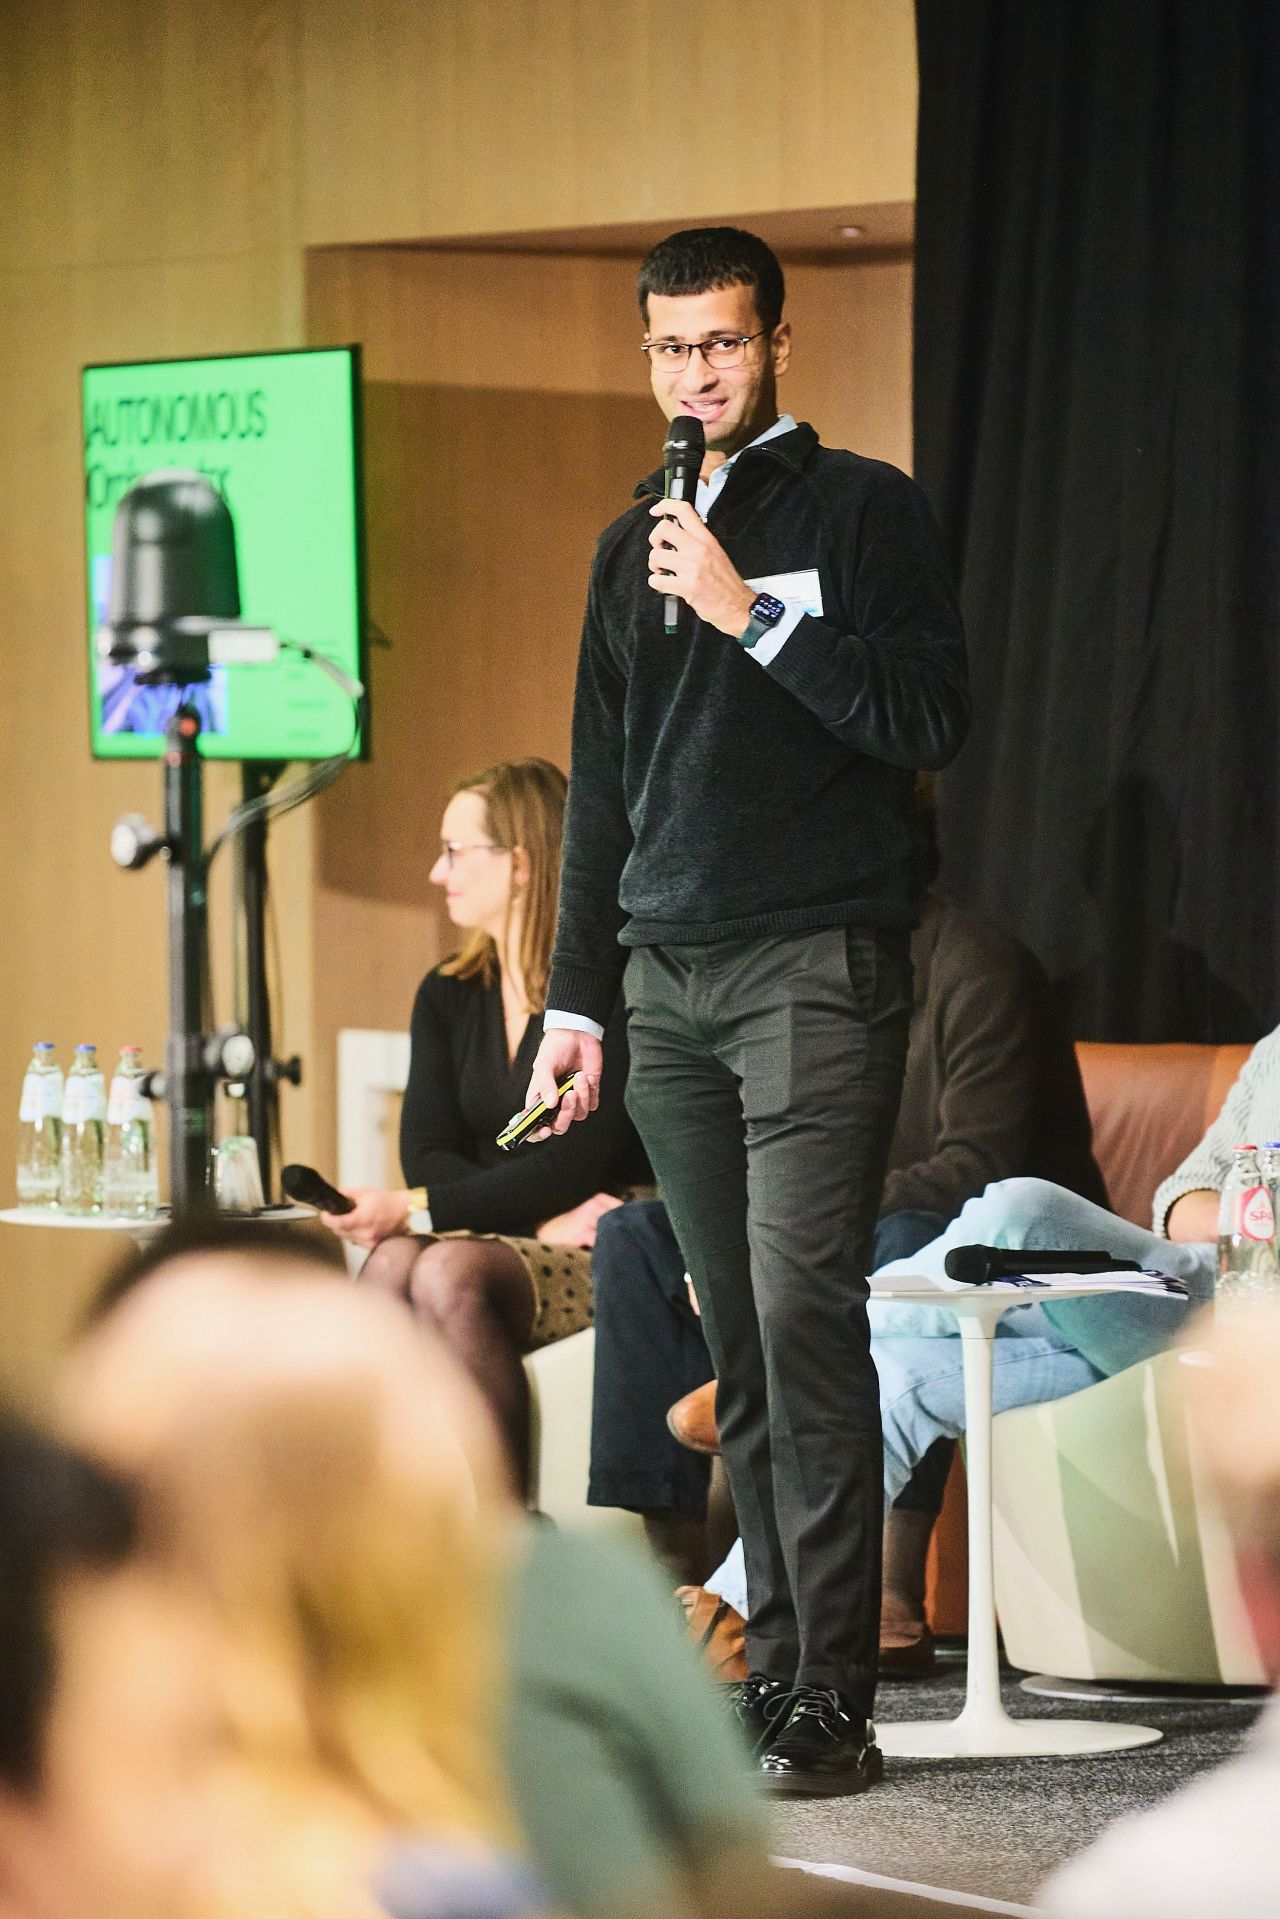 Presenting at PAVE Europe - 1st Place
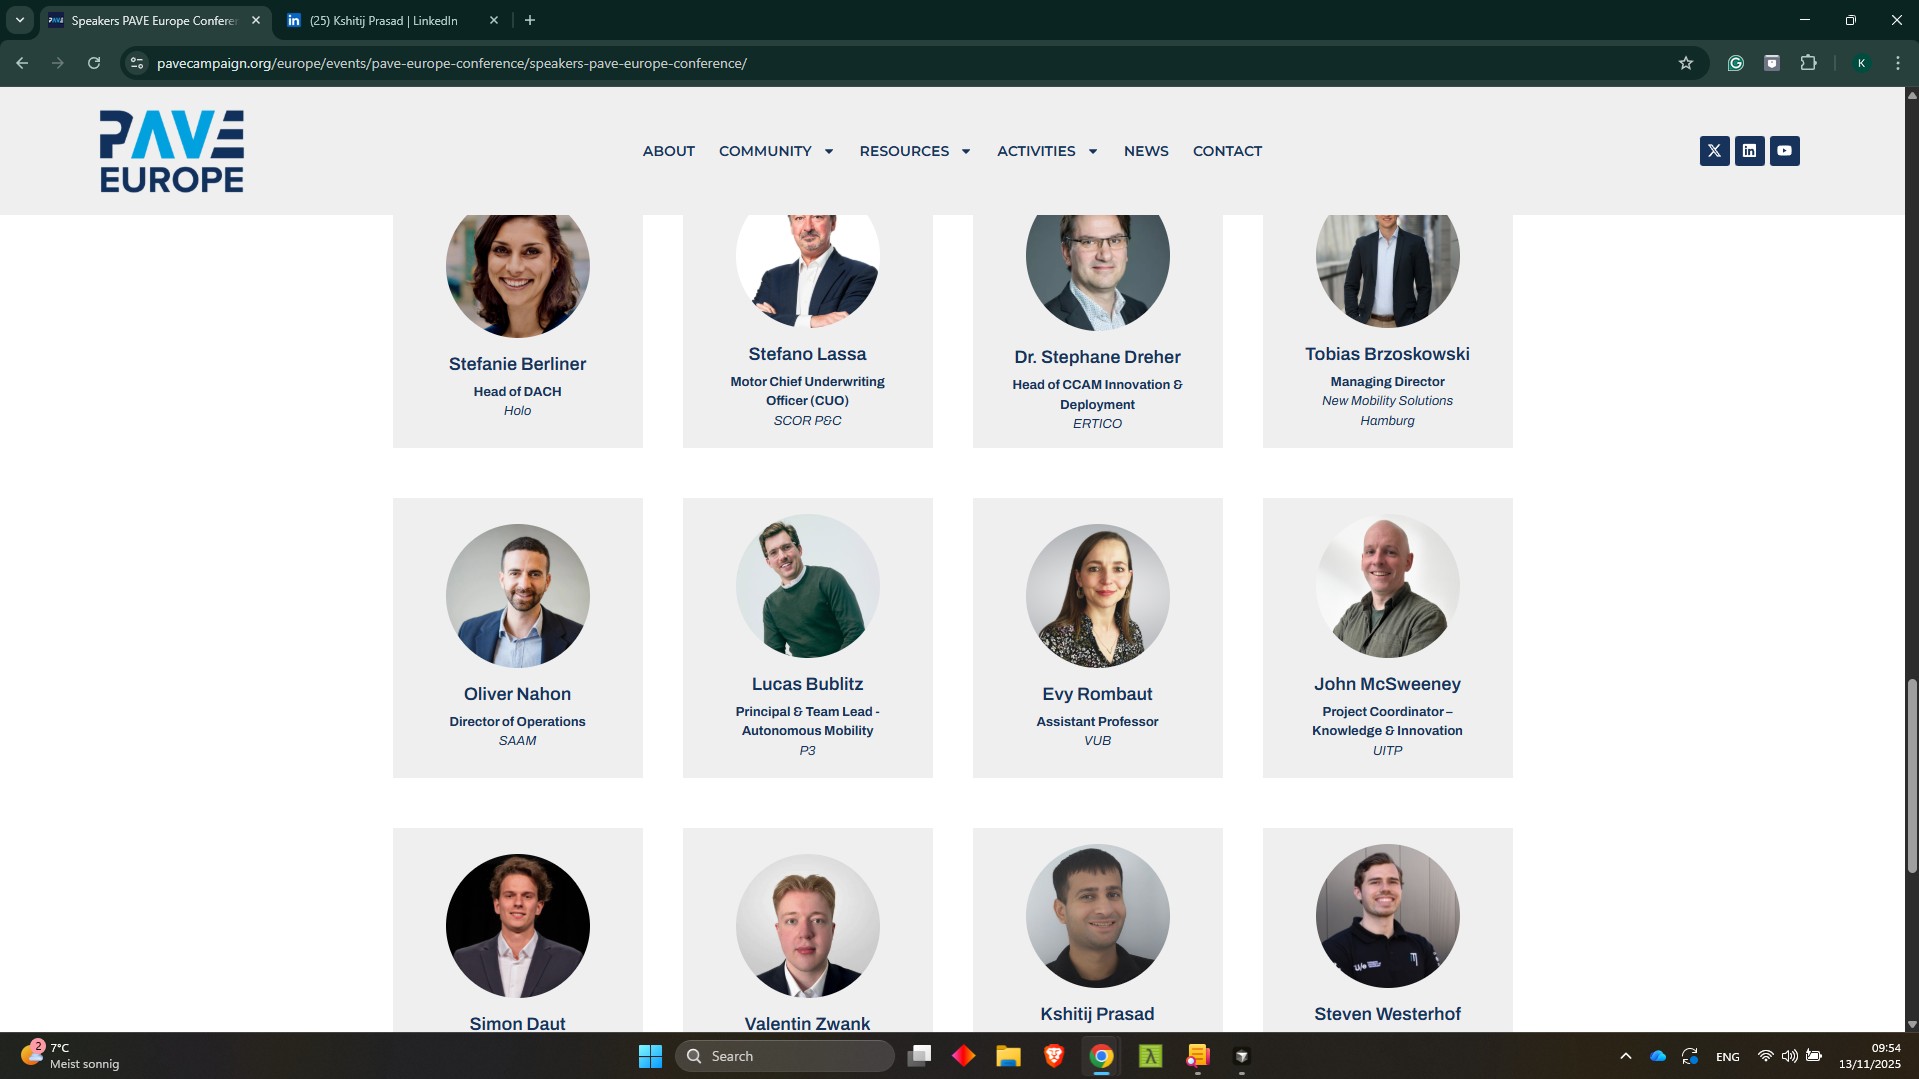 PAVE Europe Conference 2025
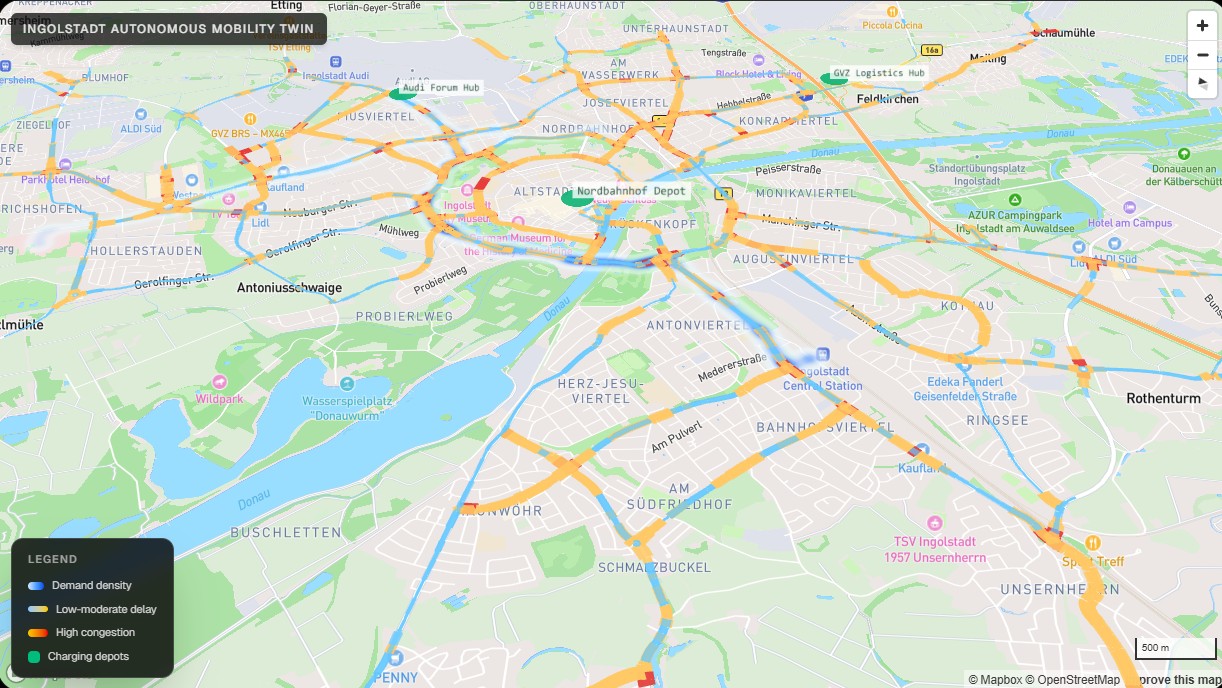
An interactive fleet-planning demonstrator combining TomTom traffic integration, simulated demand and an optional PPO backend. Bundled sample telemetry is used when live data is unavailable.
Real corridor congestion data from TomTom APIs
Optional PPO backend for a simplified fleet-demand model
Updates to simulated fleet metrics
Analysis with current transit fleet
Traffic visualisation, simulated fleet demand, route evaluation and an optional PPO backend. Scenario outputs are demonstration results rather than measured customer savings.
Formula Student Autonomous Systems Team
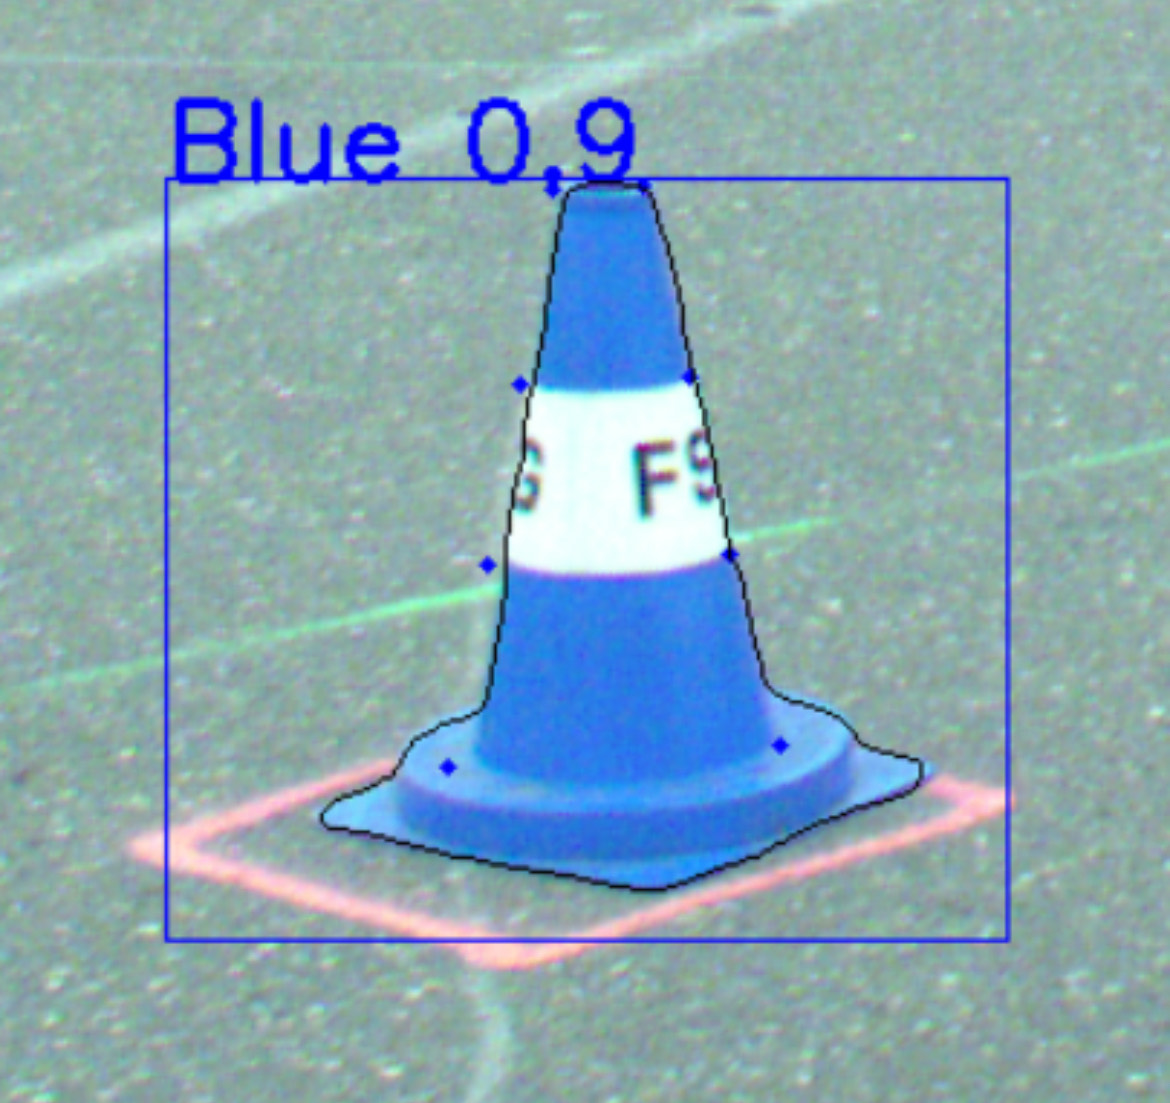
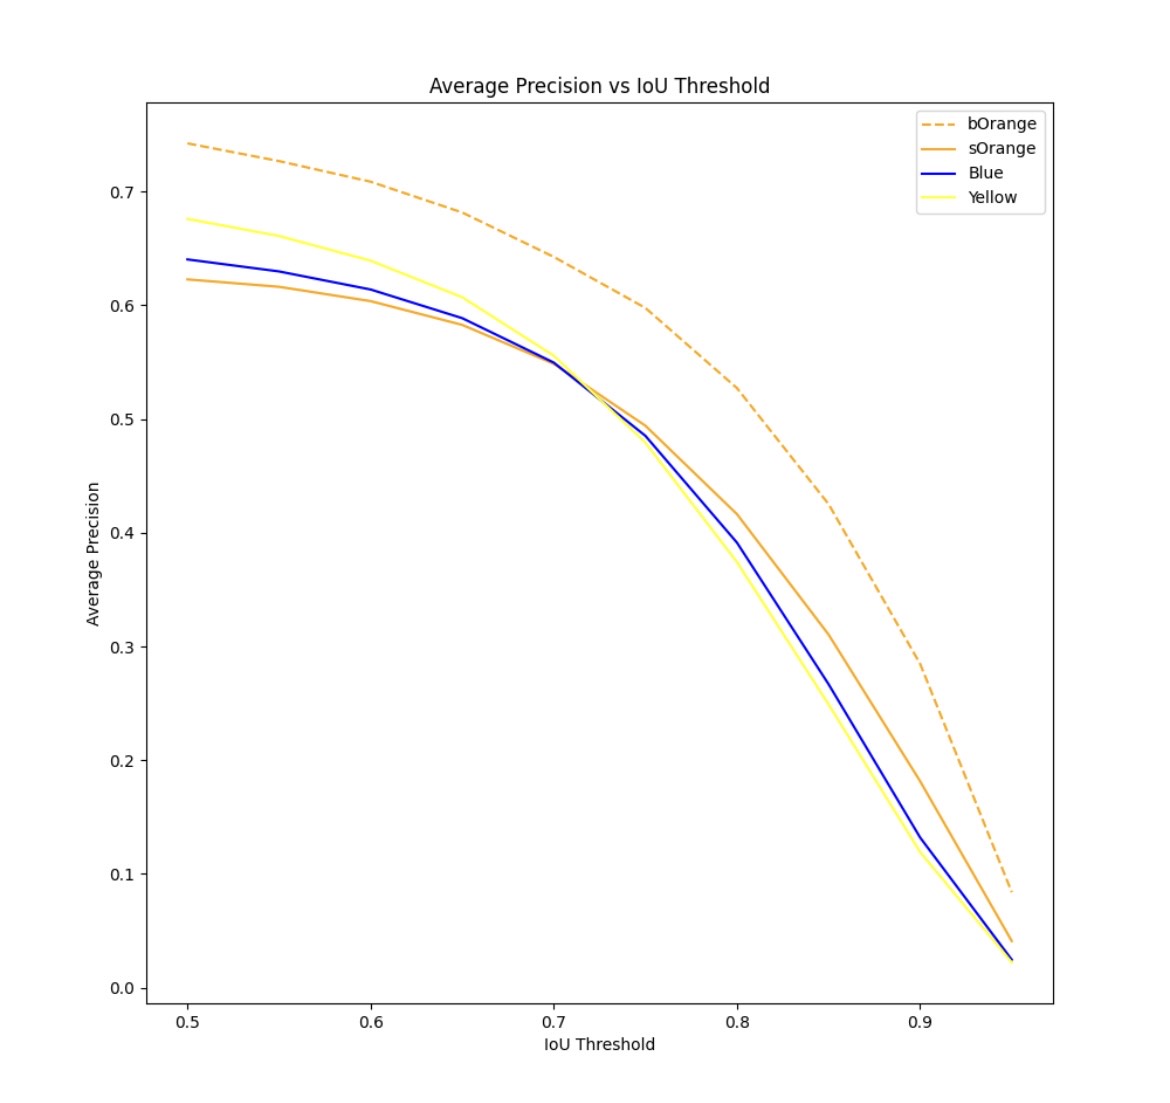
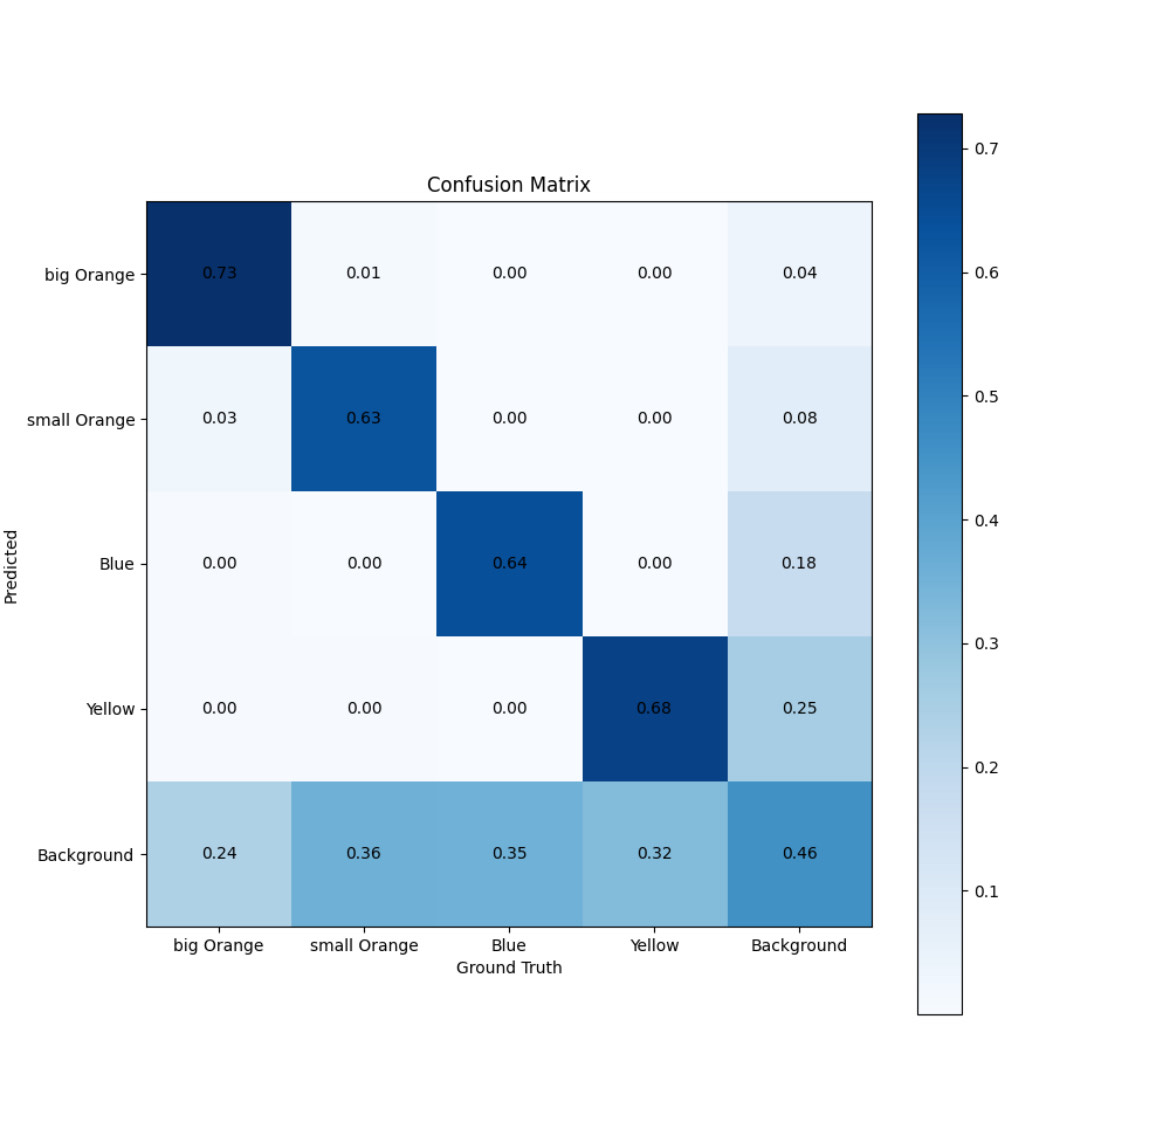
As part of the Schanzer Racing Ingolstadt Formula Student team, I contributed to developing autonomous driving capabilities for our electric race car.
Autonomous Object Detection & Retrieval System
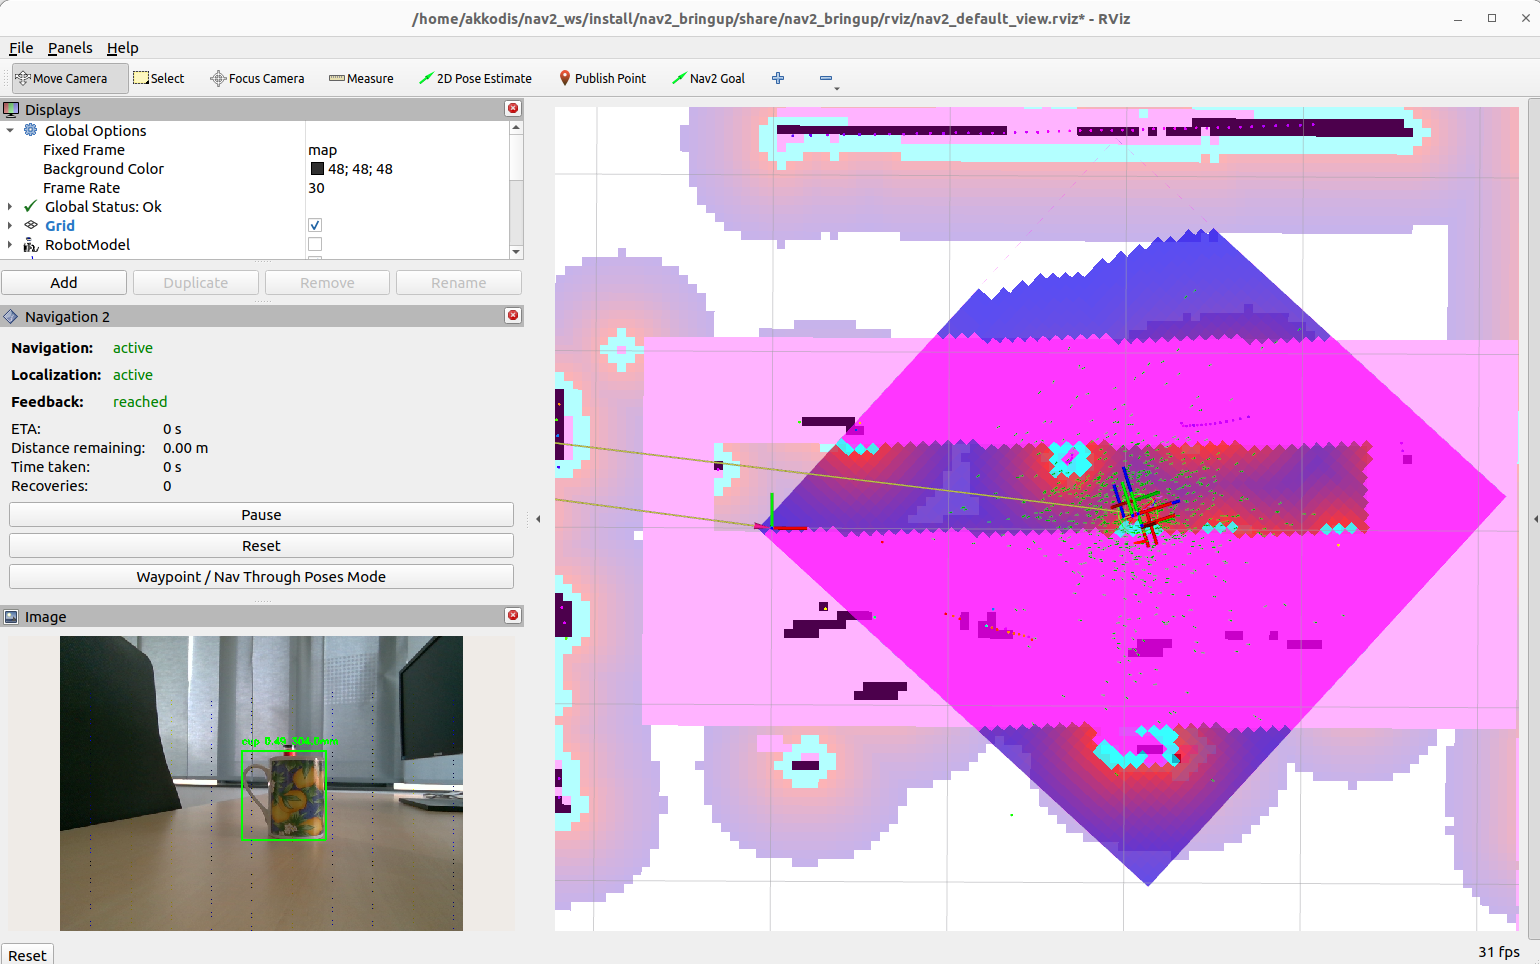
Integrated a RealSense D405 depth camera and YOLO detection with TurtleBot3 for object-retrieval tasks.
Peer-tutoring platform for TH Ingolstadt
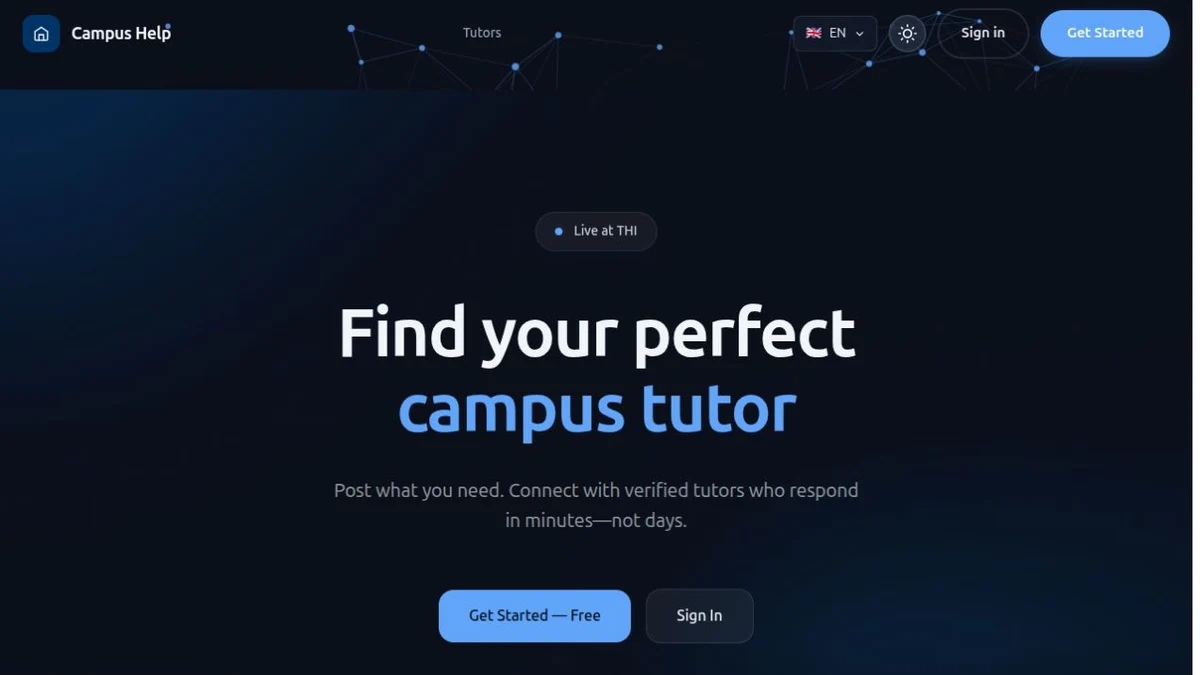
A peer-tutoring prototype for TH Ingolstadt students, with tutor discovery, requests and scheduling.
Dash-Cam & Simulation for Forensic VR Reconstruction
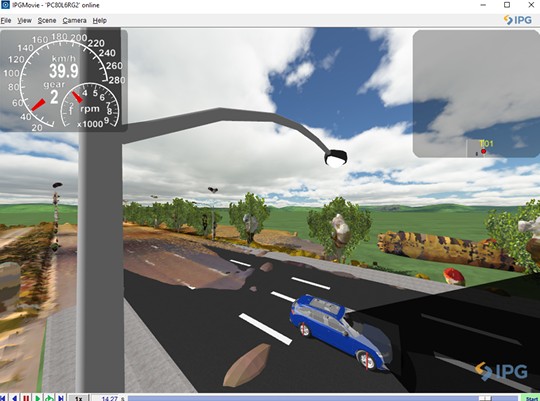
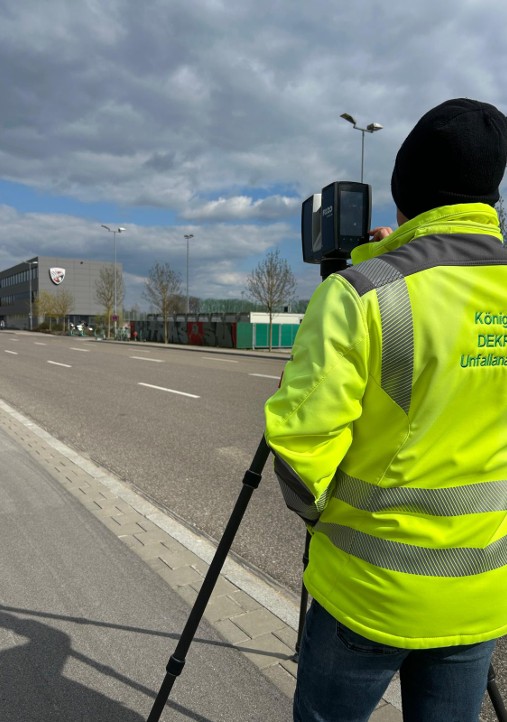 3D Laser-Scanned Scene
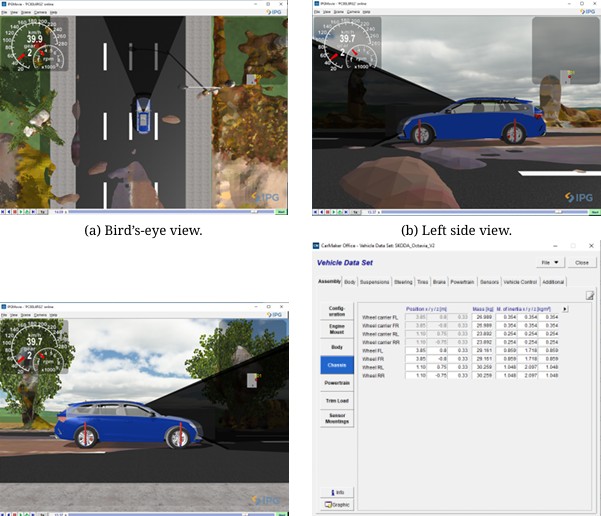 Simulation Environment
Combined dashcam footage and FARO Focus Core 3D laser scans with driving simulators for forensic VR accident reconstruction. Imported scanned point-cloud environments into IPG CarMaker, integrated a Skoda Octavia vehicle model, and aligned virtual scenarios with real-world coordinates via OpenStreetMap data. Also explored CARLA as a parallel digital twin platform.
Aerospace decision-support project
Co-developed an explainable AI decision-support prototype for the 2026 Airbus Fly Your Ideas challenge. The project combines data processing pipelines with an interface that makes model decisions easier to inspect and understand.
Vehicle telemetry · CLIP semantic search · ADAS evaluation
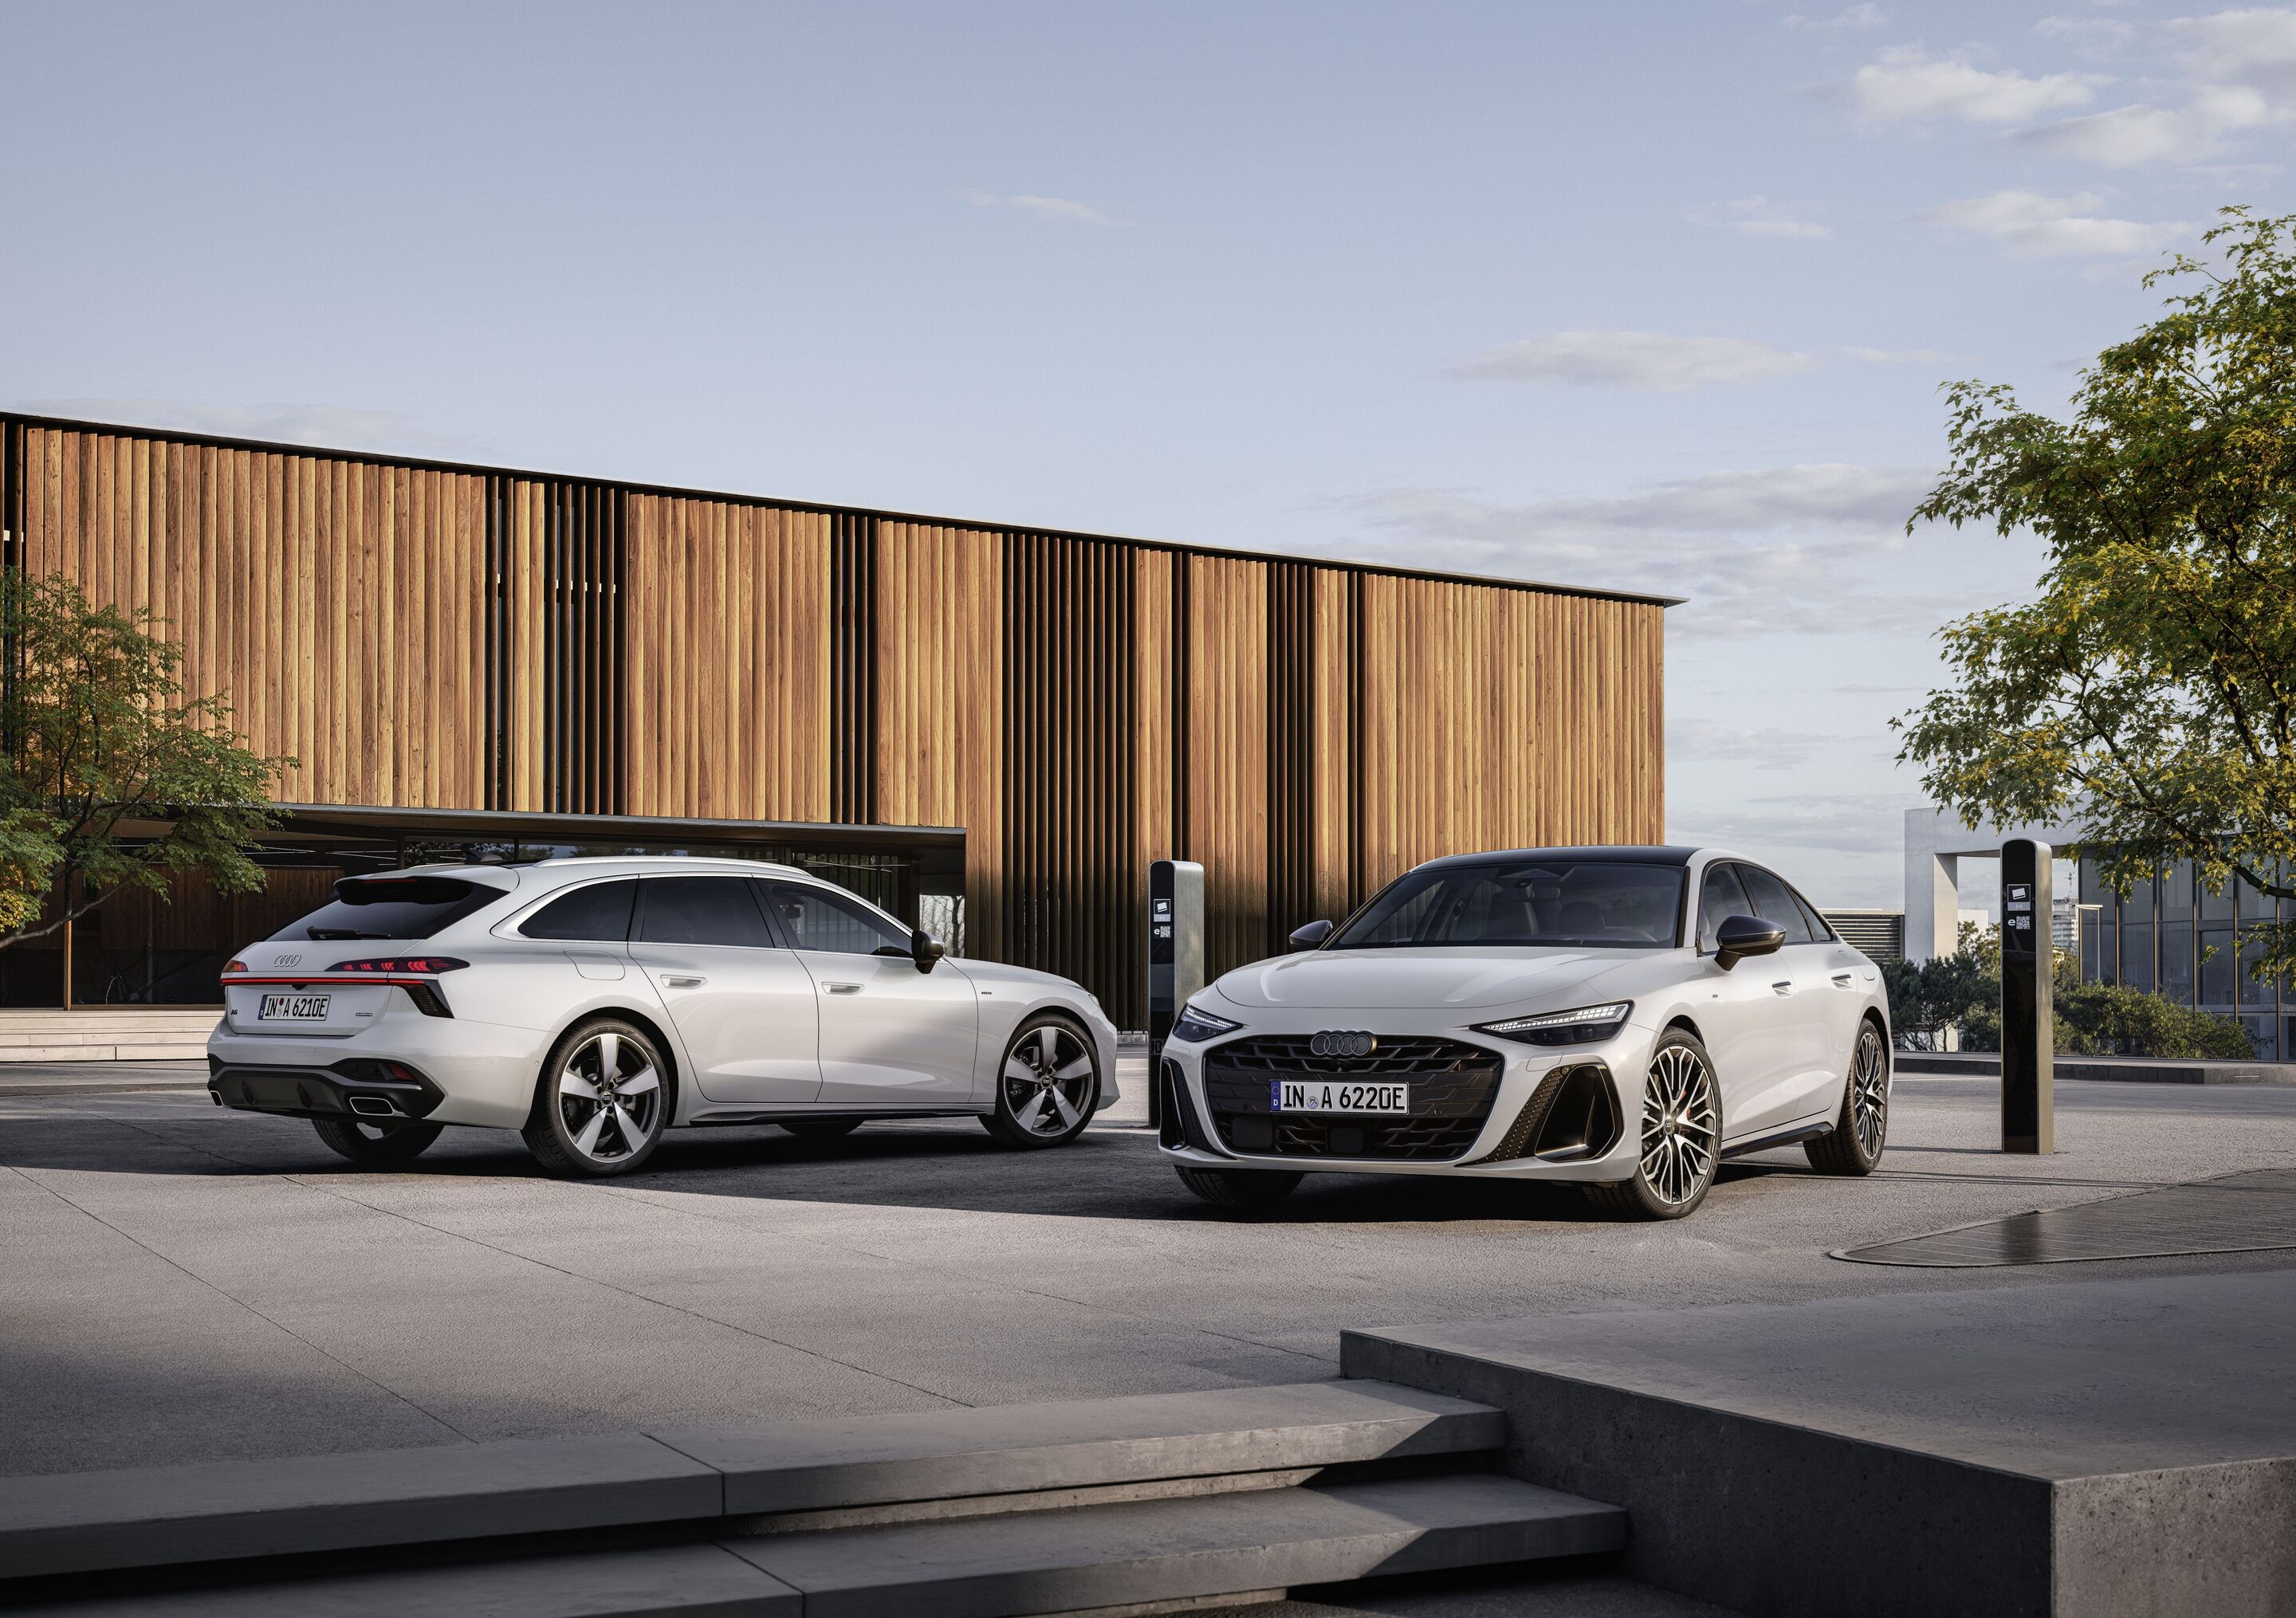
Developed Python and C++ workflows for extracting vehicle-bus and camera data, evaluating objects over time, and preparing driving scenarios for ADAS simulation.
Developed CLIP-based semantic retrieval so engineers can find driving scenarios through natural-language descriptions, then inspect the associated signals and sensor context.
The photograph provides public vehicle context. This overview describes my contribution without exposing internal tools or vehicle data.
Meal planning, groceries, and food journaling for iOS.
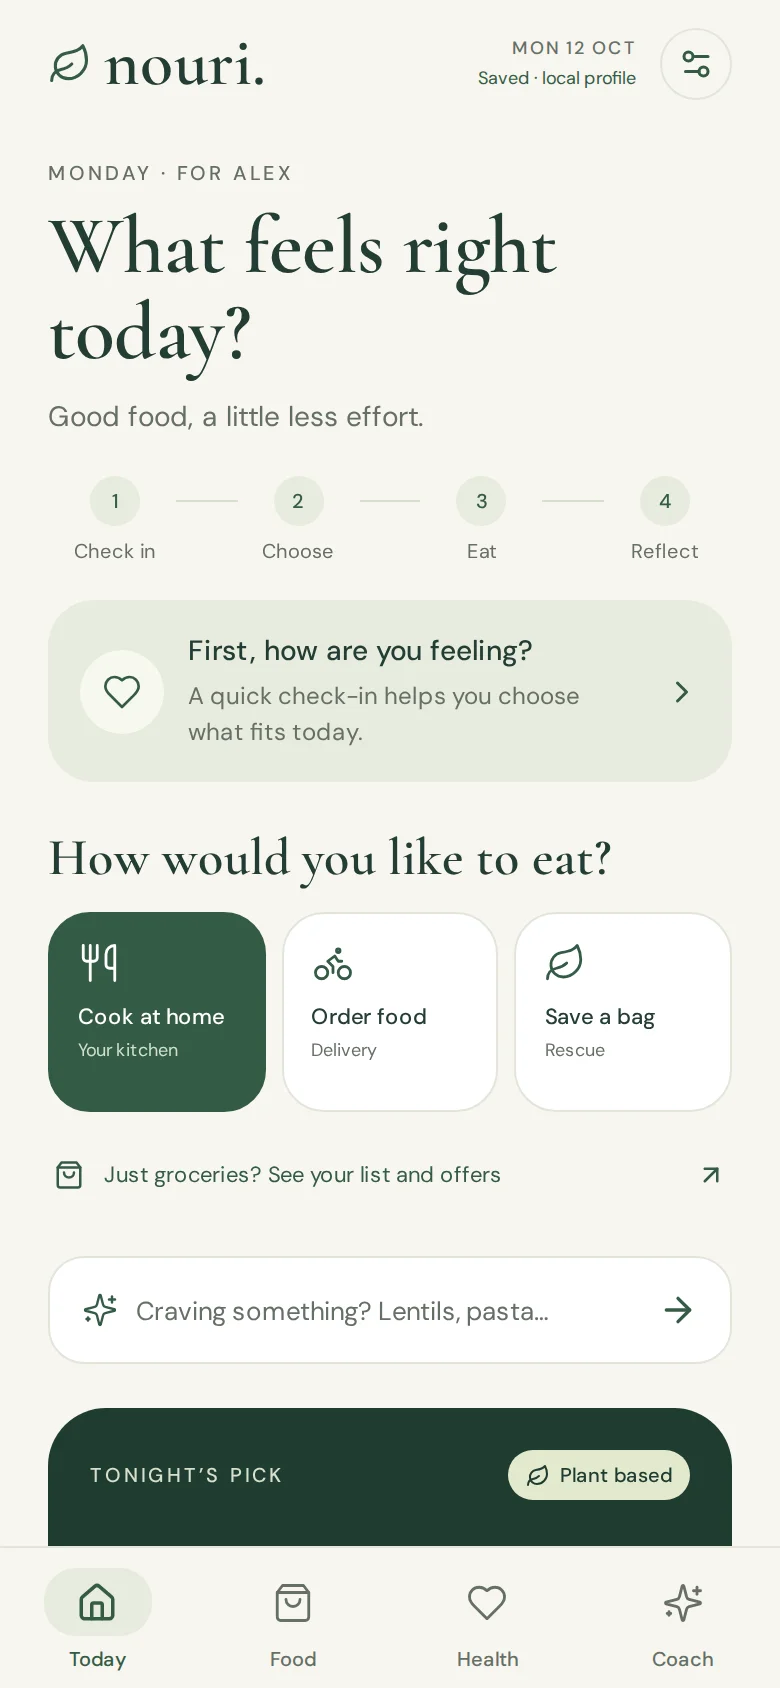
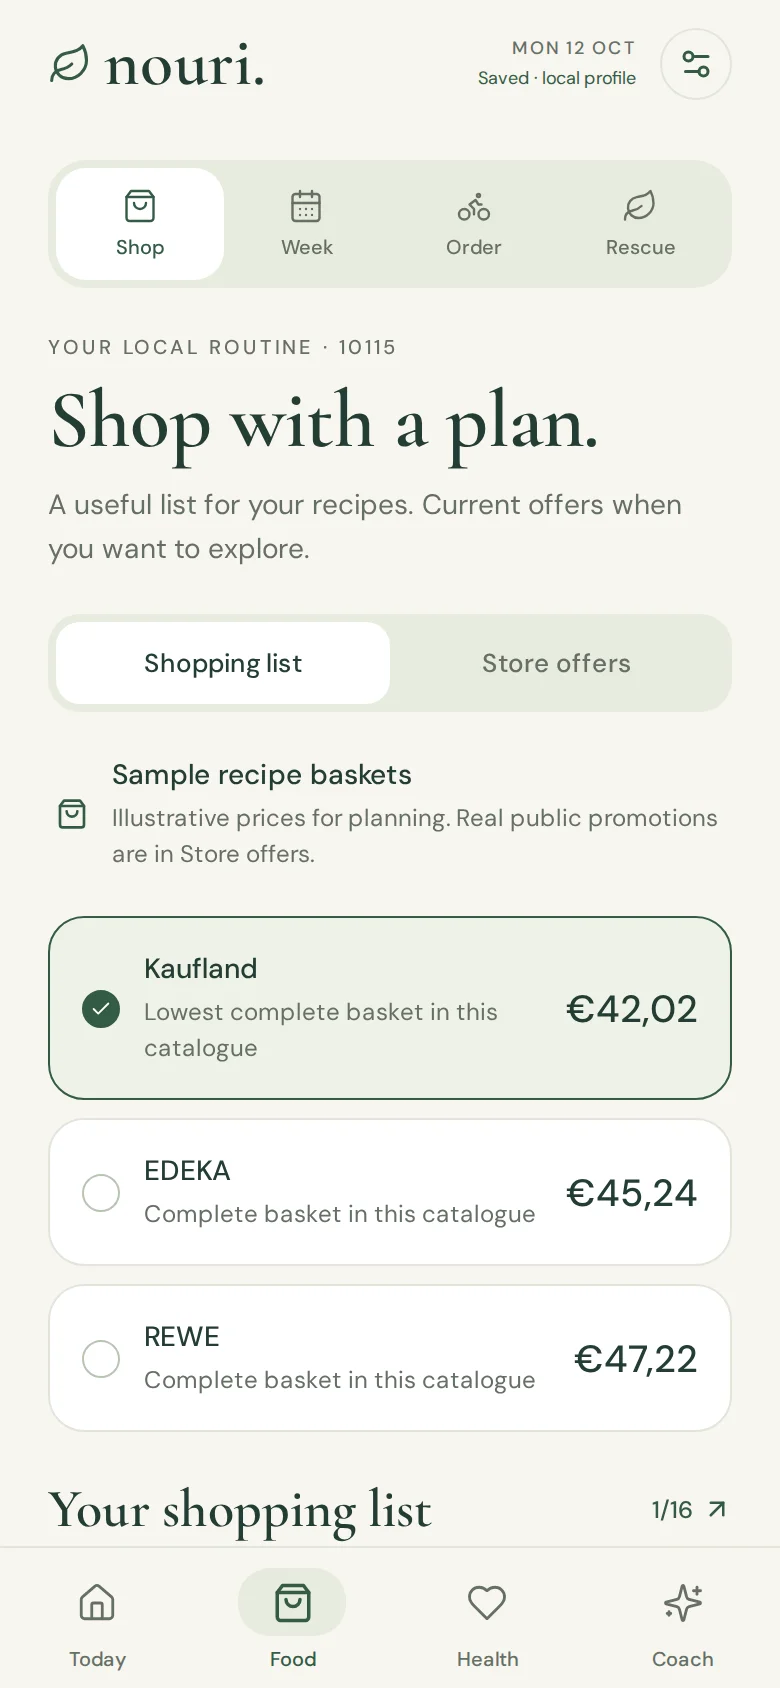
Nouri combines meal planning, grocery lists, and food journaling. Meal choices use dietary preferences, pantry selections, and a household budget.
Built with Expo, React Native and TypeScript. The app persists planning state locally and synchronizes user preferences. Optional AI generation runs on a paired computer.
Screens show sample profiles and meal choices.
Document-backed questionnaire preparation for commercial insurance renewals.
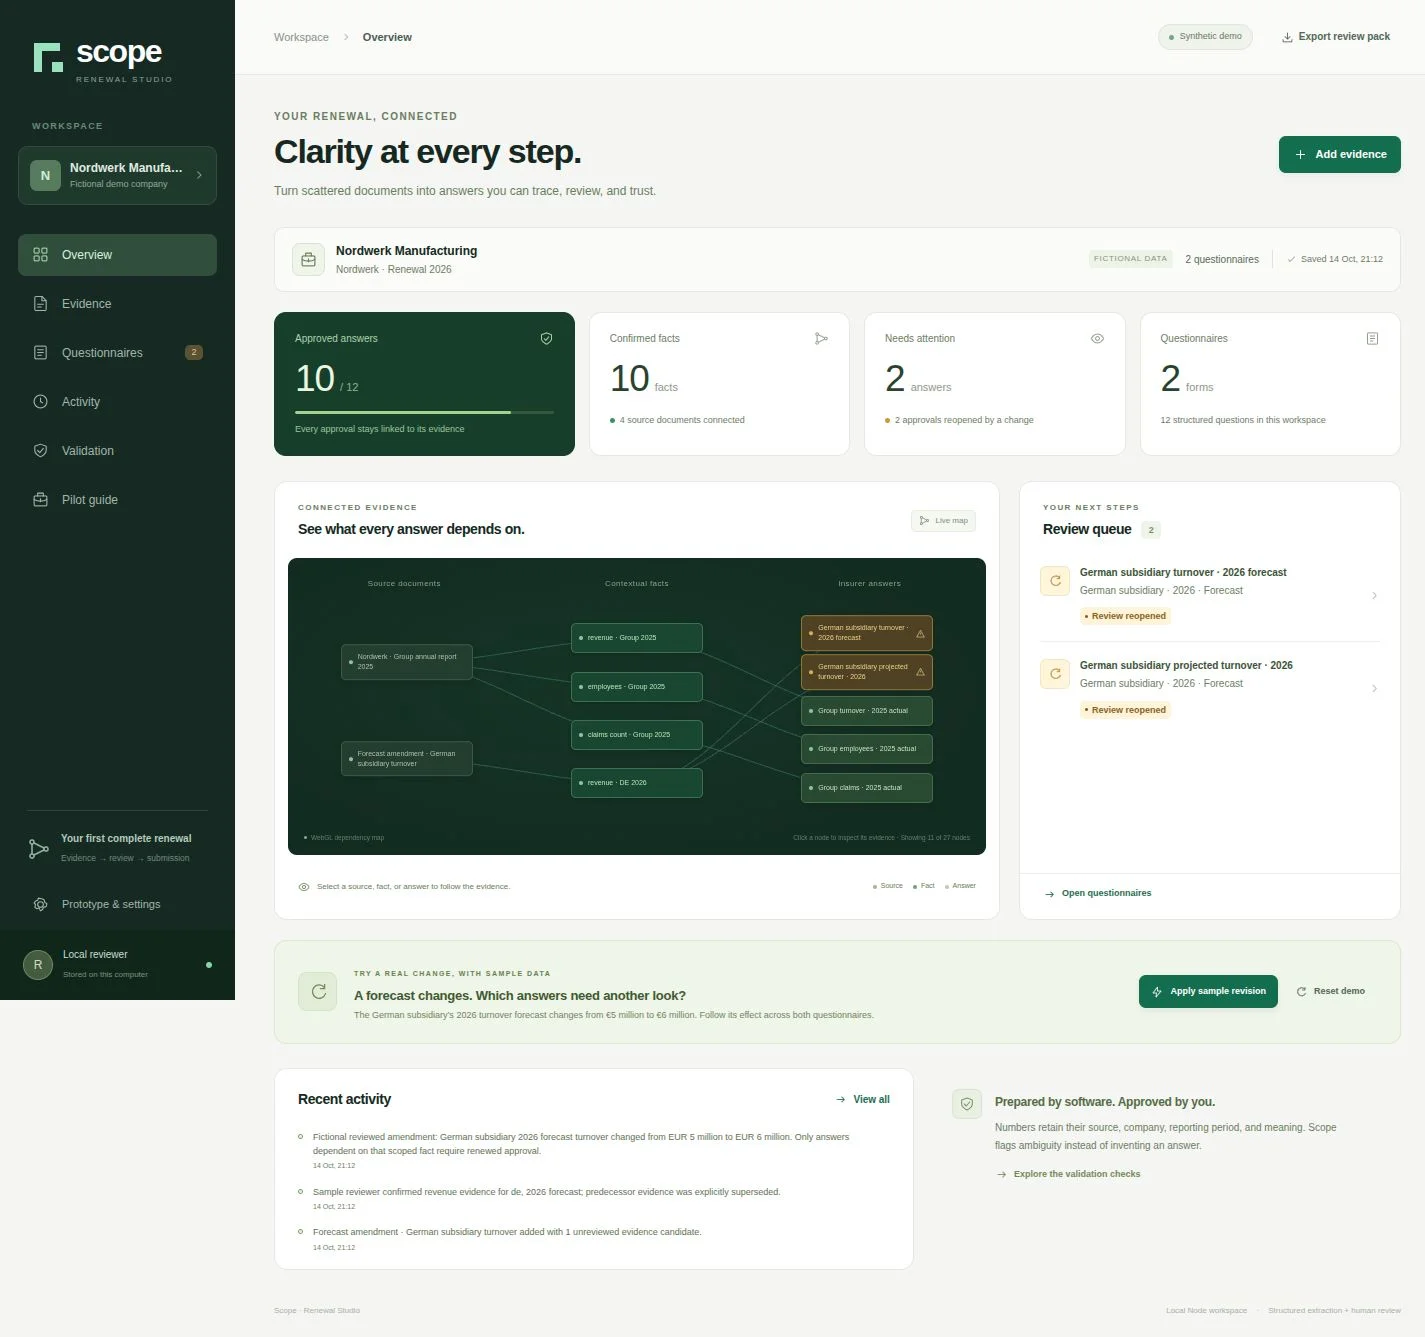
A commercial insurance renewal brings together source documents, company figures and several questionnaires. When a figure changes, the reviewer needs to see which answers depend on it and which approvals need another look.
The TypeScript API and D1-backed state model connect scoped facts, source passages, revision checks and answer approvals. A relevant change reopens the affected answers while preserving their activity history. Account-scoped persistence and transactional writes keep updates consistent.
Extraction and questionnaire mapping produce proposals. Reviewers inspect the evidence, correct the context and approve the result. Selective invalidation helps them focus on the answers affected by a change.
A working prototype using synthetic demonstration data. Customer validation and venture research are ongoing, including EXIST application preparation.